Prize winnerTeam project
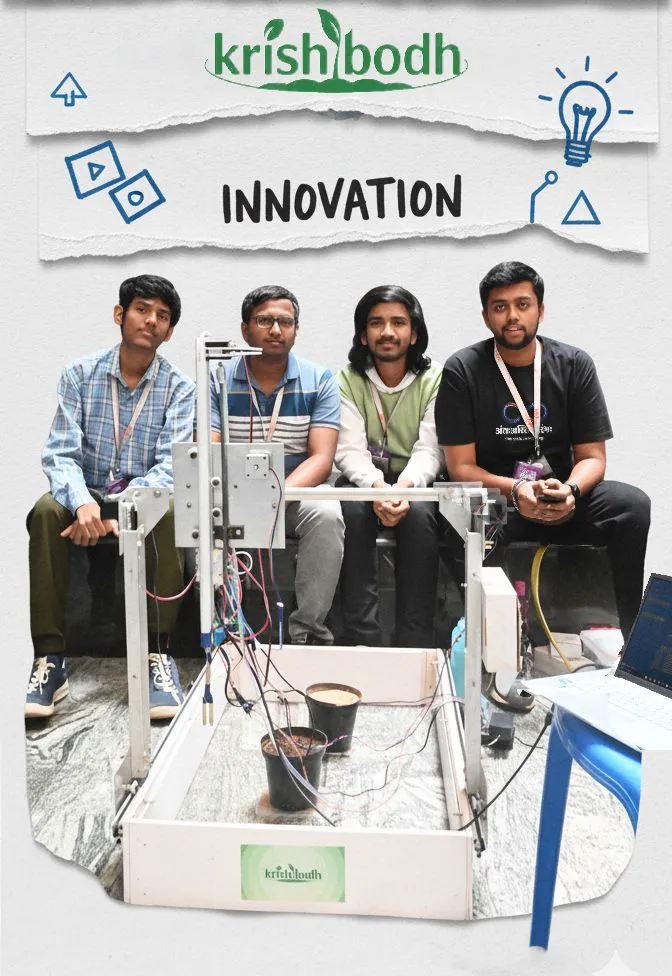
KRISHIBODH: a gantry robot that farms a plant bed
A 4-axis Cartesian robot that drives to each plant, photographs it, checks the soil and waters only when it is dry.
- 4 axesSource: Stepper setup in sketch_nov8a.ino; checked in the résumé line audit of 13 Oct 2026
- 6 serial commandsSource: Command handlers in sketch_nov8a.ino
- 96 captures, 13 runsSource: Counted *_raw.jpg files and demo_runs folders in the repo
The problem
Small growers water on a schedule, not on need, and nobody looks at every plant every day. We wanted a machine that visits each plant, measures it, and acts on what it finds.
What was built
- Arduino C++ firmware drives NEMA 17 steppers on four axes, with two motors sharing the X gantry, using acceleration-limited moves.Source: sketch_nov8a.ino (AccelStepper); NEMA 17 per the March 2025 project draft open
- A serial protocol of six commands (MOVE, SMART, WATER, FORCE_WATER, MOISTURE:GET, MODE) with a manual override that works mid-move.Source: Command handlers in sketch_nov8a.ino
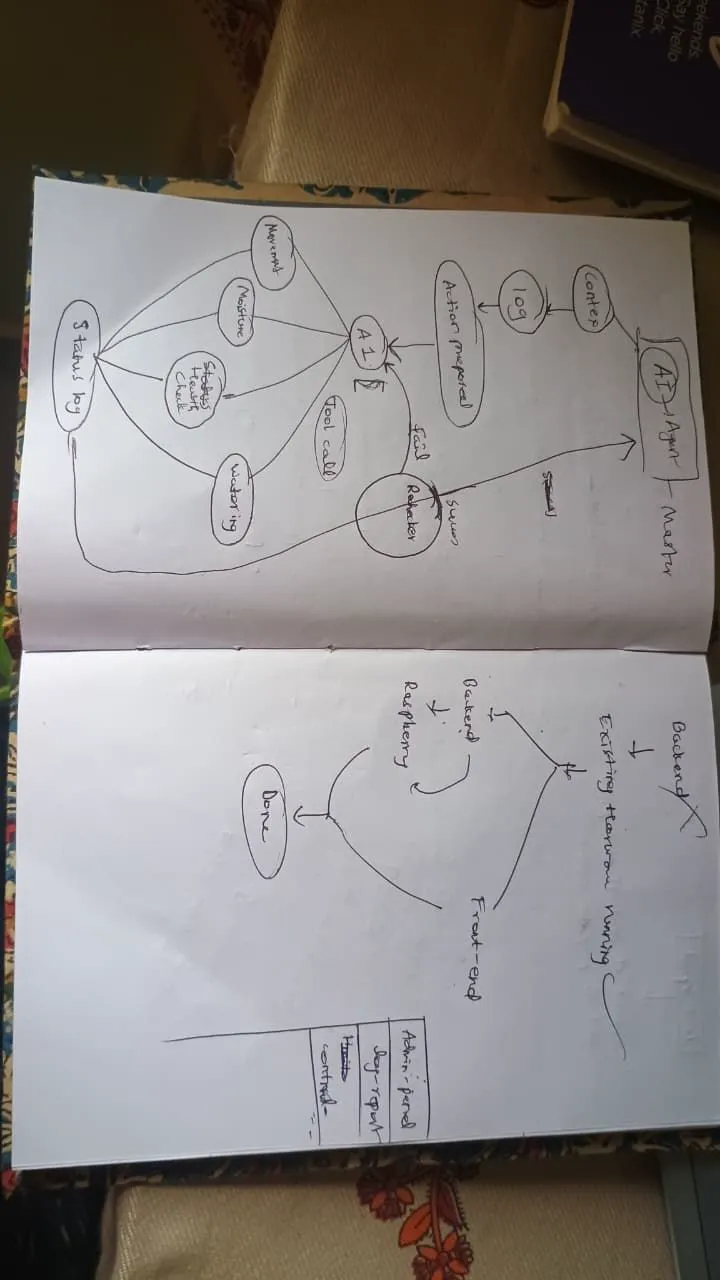
- A thread-safe Python control plane: a background serial listener waits for the firmware's ready signal, then triggers the top and side cameras.Source: arduino_service.py: lock-guarded singleton, daemon listener, capture on "Ready for next command"
- Leaf health scoring with U²-Net segmentation and an HSV fallback, run over 96 captures in 13 logged experiment runs.Source: camera/analytics.py (rembg uses U²-Net); counted 96 *_raw.jpg files and 13 demo_runs folders
- A Gemini assistant turns plain English ("Plant 2 is dying") into a schema-constrained robot command, and turns a hypothesis into a JSON experiment the robot runs.Source: chatbot.html system prompt and responseSchema; routes.py /generate_plans
What this does not show
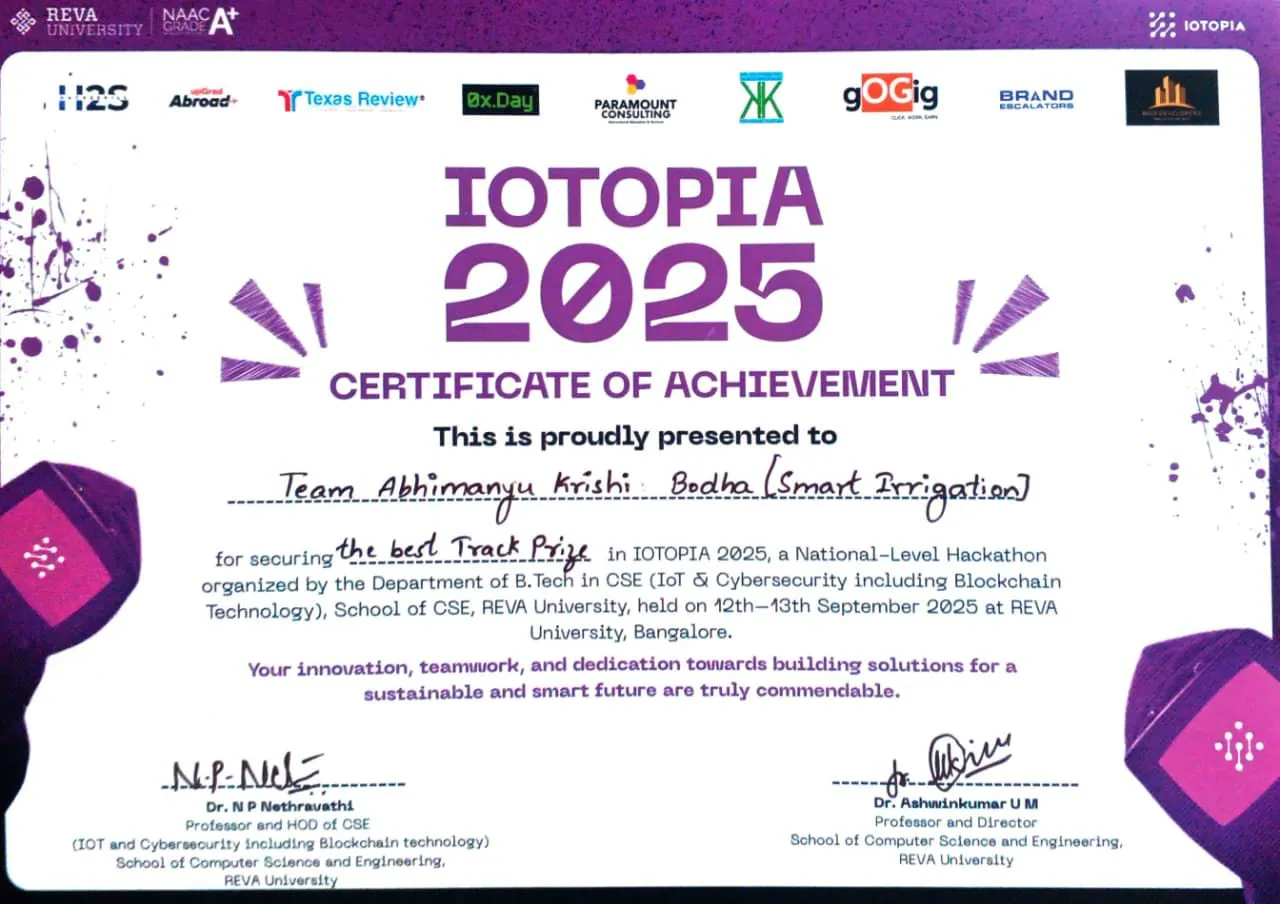
- This was a hackathon team build (Team Abhimanyu), not a solo project.
- The control software runs as Flask on a PC talking to the Arduino over serial. It is not an embedded Linux deployment.
- Leaf health is a colour and segmentation score. It is not a trained disease classifier, and I quote no accuracy for it.
Receipts
ClaimWhere it comes from
4 axesStepper setup in sketch_nov8a.ino; checked in the résumé line audit of 13 Oct 2026
6 serial commandsCommand handlers in sketch_nov8a.ino
96 captures, 13 runsCounted *_raw.jpg files and demo_runs folders in the repo
Arduino C++ firmware drives NEMA 17 steppers on four axes, with two motors sharing the X gantry, using acceleration-limited moves.sketch_nov8a.ino (AccelStepper); NEMA 17 per the March 2025 project draft open
A serial protocol of six commands (MOVE, SMART, WATER, FORCE_WATER, MOISTURE:GET, MODE) with a manual override that works mid-move.Command handlers in sketch_nov8a.ino
A thread-safe Python control plane: a background serial listener waits for the firmware's ready signal, then triggers the top and side cameras.arduino_service.py: lock-guarded singleton, daemon listener, capture on "Ready for next command"
Leaf health scoring with U²-Net segmentation and an HSV fallback, run over 96 captures in 13 logged experiment runs.camera/analytics.py (rembg uses U²-Net); counted 96 *_raw.jpg files and 13 demo_runs folders
A Gemini assistant turns plain English ("Plant 2 is dying") into a schema-constrained robot command, and turns a hypothesis into a JSON experiment the robot runs.chatbot.html system prompt and responseSchema; routes.py /generate_plans